Technical writing for plant managers, not press releases.
Deployment walkthroughs, retask case notes, integration guides, and safety zone setup. Written by engineers who install these arms.
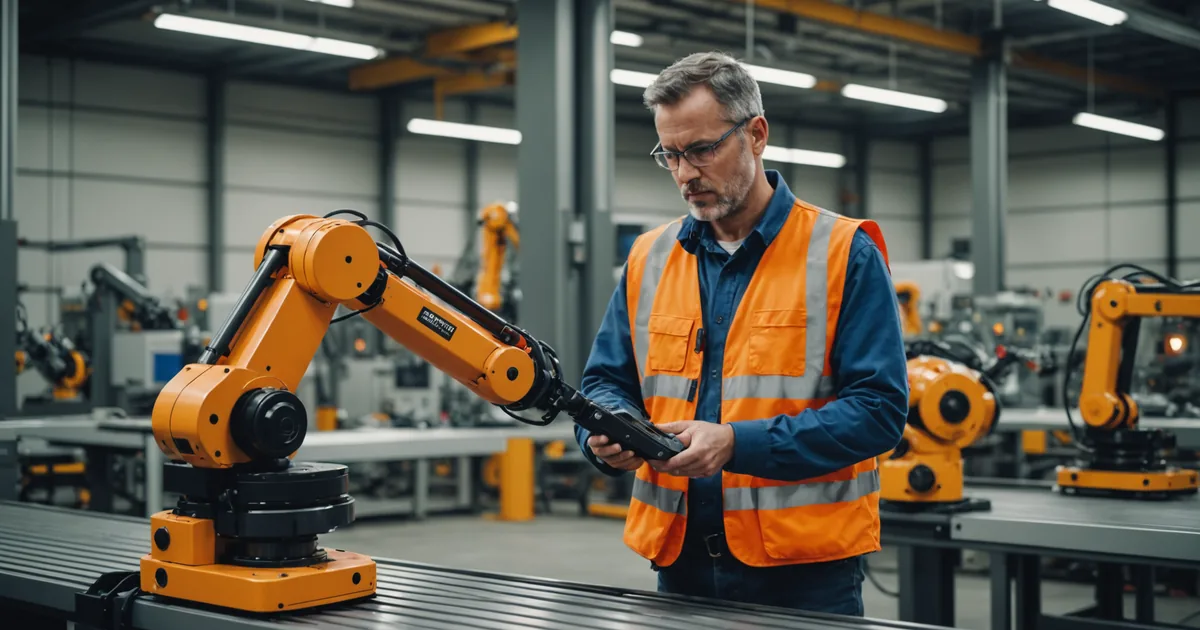
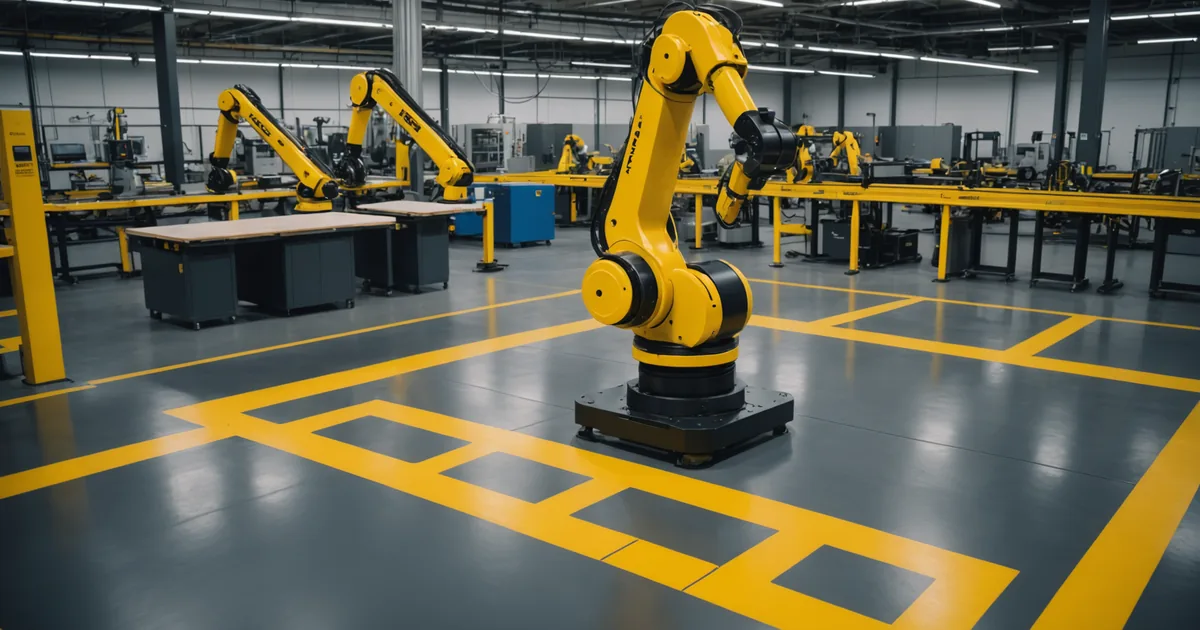
Cobot Safety Zones on the Plant Floor: What Actually Matters
Speed and separation monitoring, collaborative stop, and power-and-force limiting. Which mode applies to which station, and how the zone parameters get set during commissioning.
Retasking vs Reprogramming: The Real Difference
Reprogramming means writing new motion code. Retasking means teaching the arm a new job through guided demonstration. One requires an integrator; the other does not. This is the core distinction that matters for mid-size plants.
Five Manual Stations Worth Automating First
Not every manual station is the right first candidate for a robot arm. These five station types have predictable pick geometry, manageable variability, and strong ROI on a 12-month horizon for most Tier-2 and Tier-3 plants.
Robot Arm ROI in Small-Batch Manufacturing
How to frame the ROI calculation for a plant running mixed products on short runs. Labor hours per task, changeover downtime cost, integrator engagement cost removed, and what changes when the arm pays for itself by end of year two.
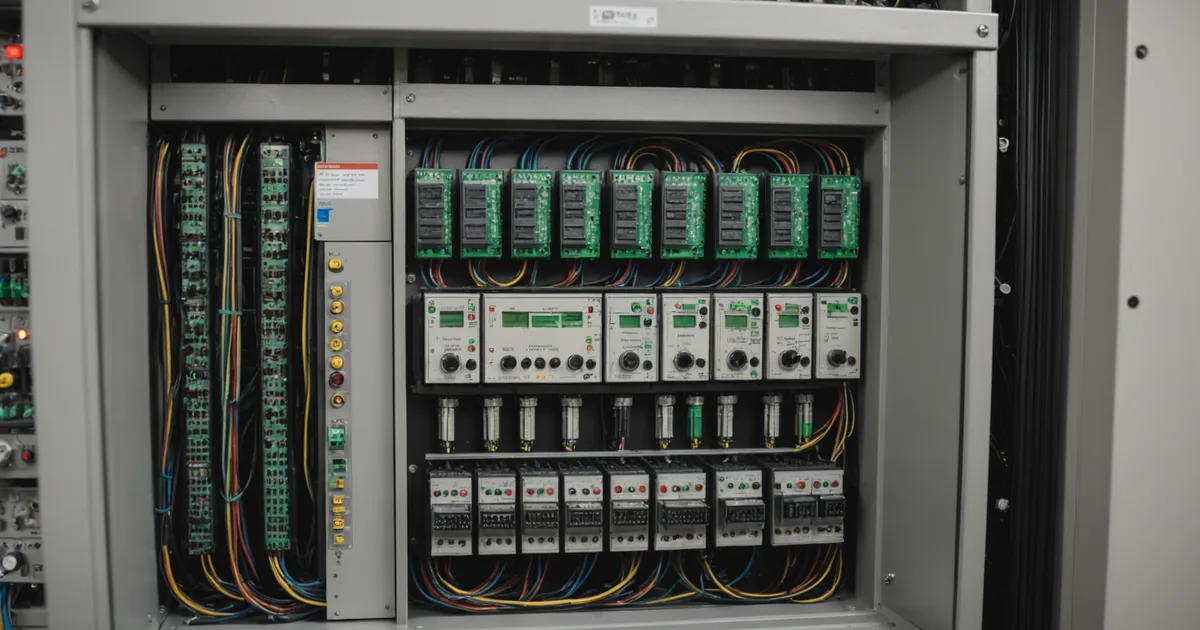
EtherNet/IP and Modbus TCP Cobot Integration: A Field Guide
Step-by-step I/O handshake setup for Allen-Bradley, Siemens, and Mitsubishi PLCs. What the cobot expects, what the PLC sends, and what the most common wiring errors look like in the diagnostics.
Palletizing Station Changeover: Case Notes from a Product Switch
A Midwest automotive supplier changed box sizes mid-week. The arm retasked in 2.5 hours. These are the notes from the teach session including what the pallet pattern editor showed and where the first run needed correction.
Visual Teach Mode Explained: What Happens When You Guide the Arm
When an operator guides the arm by hand, the depth camera and inertial system record waypoints, collision geometry, and velocity constraints simultaneously. This is what the system stores and how it generates the trajectory from the recorded path.
Why Detroit Matters for Industrial Robotics
Most robotics startups build for Tier-1 suppliers with long automation contracts. The Tier-2 and Tier-3 plants that make up most of the supply chain got left out of that market. That is the problem this company was built to fix, and why it is based here.
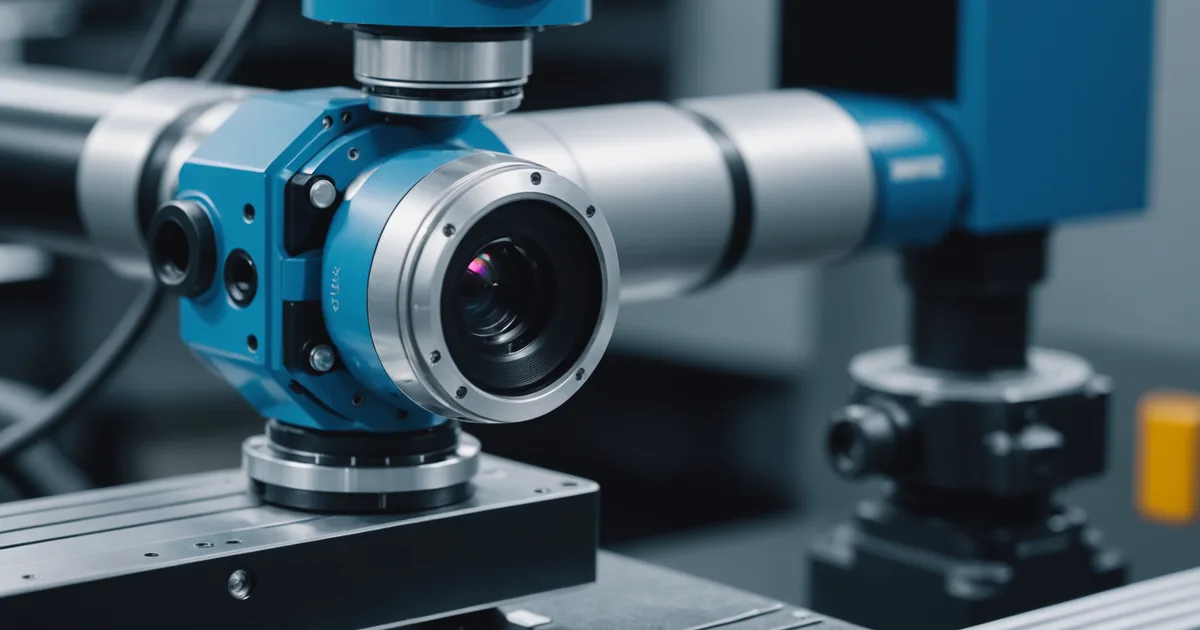
Assembly Assist and Depth Camera Quality Check: Two Tasks at One Station
Running assembly assist and quality inspection at the same station across different shifts requires two separate task configurations. This post covers how the arm stores both, and what changes in the teach session for each.
Integrator-Free Deployment: What It Actually Takes
The hardware arrives. Commissioning starts. This is a real account of what the plant side needs to provide, what happens on-site during the installation day, and what the first operator teach session looks like in practice.
The Early Access Program: What We Learned from 8 Pilot Sites
Eight plants. Four task types. Twelve retask events. This is what we learned from the first cohort of early-access customers about what the arm does well, where the teach process takes longer than expected, and what we changed based on field feedback.